Build a quadruped robot for under €500
Twelve servos, a controller, a power stage and a frame. The parts list below is rebuilt from live stock every time this page loads.
IntermediateTarget budget €500.00From €36.80 with the cheapest option at every step
1.The twelve joint servos× 12
Three degrees of freedom per leg. Aim for at least 20 kg·cm of torque and metal gears — plastic gears strip within hours on a walking robot.


2.Controller board
Twelve PWM channels minimum. A dedicated servo driver offloads the timing from the main board, which matters once you add gait computation.

RobotShopIn stock
Contrôleur de Servomoteurs PWM 16 Canaux pour Raspberry Pi Waveshare
€17.31Rated 5.0 out of 5, 2 reviews
View at seller ↗
RobotShopIn stock
Contrôleur de Servomoteurs PWM 16 Canaux PCA9685
€13.19Rated 4.8 out of 5, 12 reviews
View at seller ↗

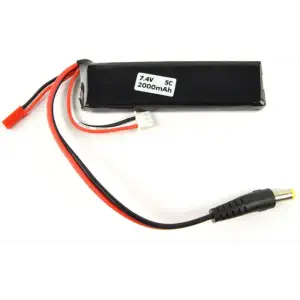
3.Power stage
Twelve servos under load draw far more than a USB port provides. Size the battery for peak stall current, not average draw.


4.Frame and hardware
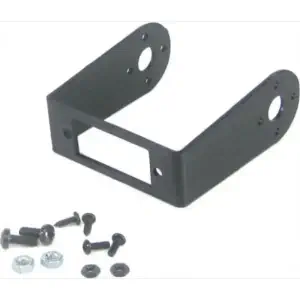
Aluminium brackets sized for your servo family. Buy the matching horn set at the same time — it is the part everyone forgets.


Parts are selected by the search engine on price, stock and specifications, never on affiliate commission. Robotitem does not test these products.